Research
"Seeing is believing" no longer holds in an era saturated with generative AI and autonomous agents. I build full-stack systems that restore trust by establishing a verifiable chain of custody, from raw physical capture to consumption and actuation. My work is grounded in digital provenance and extends that principle to physical AI, where safe autonomy demands verifiable sensor data, authenticated commands, and contract-bound execution.
Verifiable Digital Provenance
Can we trust what a camera saw? I build provenance systems that let anyone verify where media and data came from, from trusted computing bases inside the camera to defenses against recapture attacks and provenance for machine learning data.
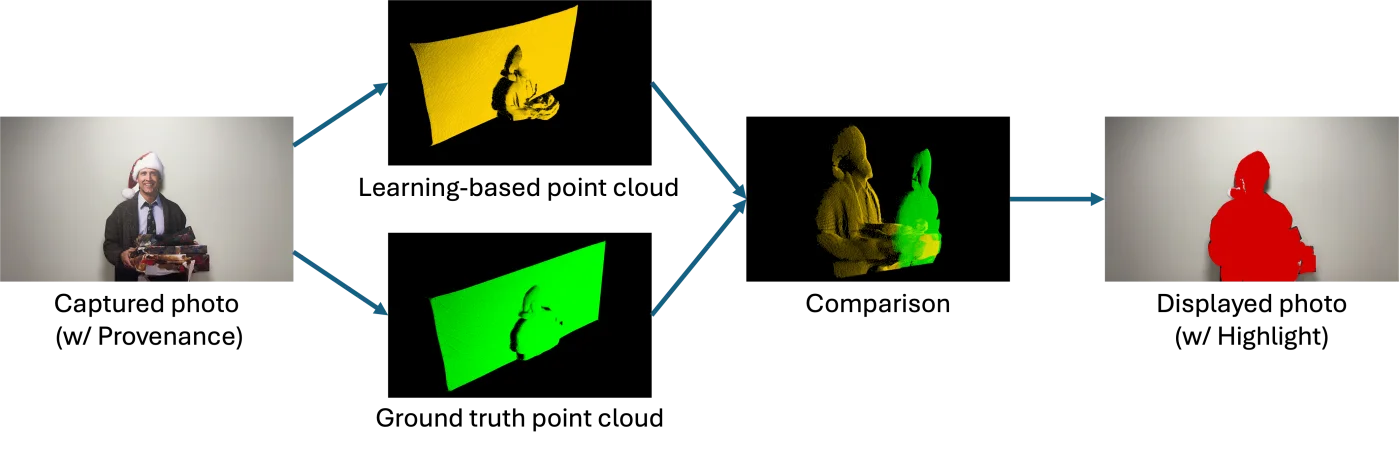
- Scoop: detecting recapture attacks, where fake footage shown on a screen is filmed by a provenance-enabled camera. USENIX Security'25 · ACM GetMobile Research Highlight [Paper] [GetMobile Highlight] [Code] [Poster]
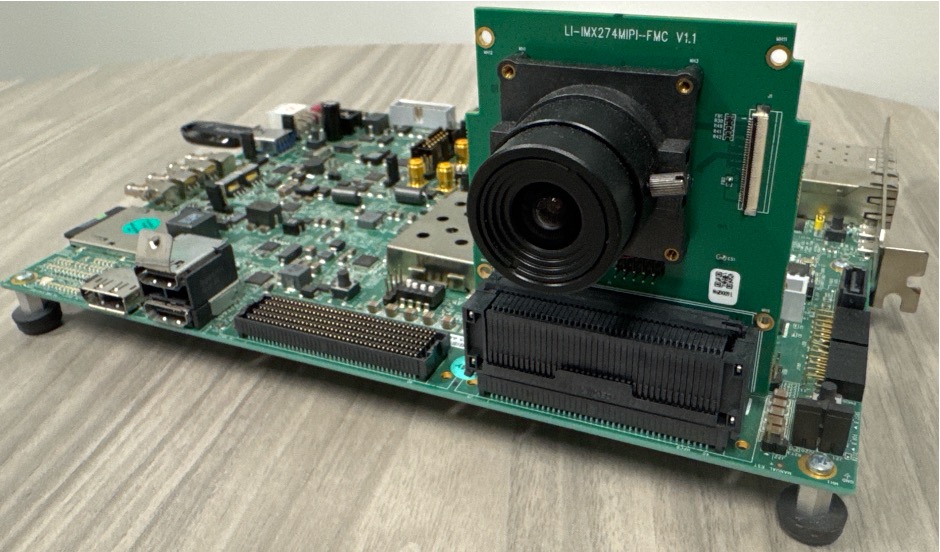
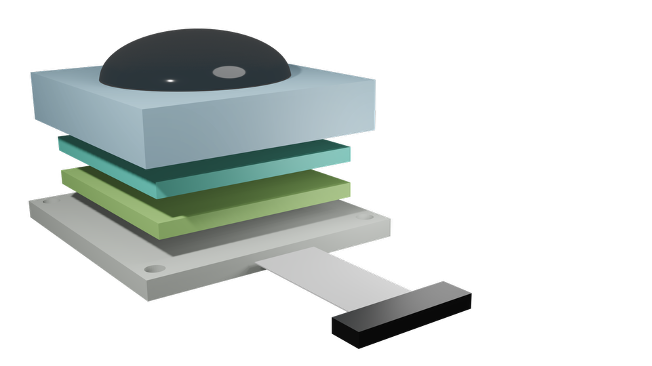
- ProvCam: a camera module with a self-contained trusted computing base that produces verifiable videos. MobiCom'24 [Paper] [Code]
- Vronicle: verifiable provenance for videos captured and edited on mobile devices. MobiSys'22 · Best Poster Award Runner-up [Paper] [Code] [Poster]
- Ongoing Semantic provenance for live video chat; confidential, verifiable provenance for machine learning data.
Trustworthy Physical AI
As robots driven by foundation models move into public spaces, they must verify whom they obey and bound what they do. I bring provenance and hardware-rooted trust to robot perception, command, and actuation.
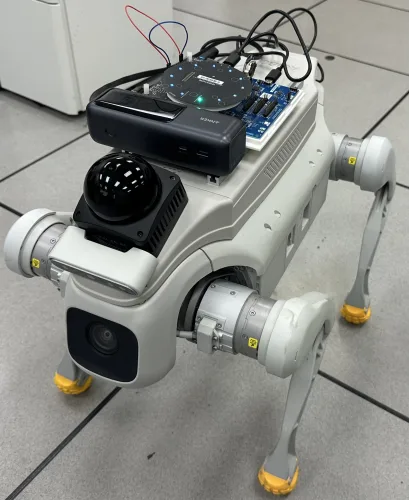
- RoboAuth: authenticating emergency robot overrides by cross-checking secure RF ranging, depth sensing, and acoustics, each signed at capture. ACSAC'26 Poster [Poster Proposal]
- Ongoing Contract-bound safety enforcement for robots driven by foundation models.
Hardware & OS Foundations
The trusted hardware and operating system mechanisms that the work above builds on.
- Patchlings: safety-preserving hotpatching for real-time automotive microcontrollers, in collaboration with Bosch Research. arXiv [Paper]
- UnderRansom: real-time ransomware detection and mitigation in the OS kernel, developed at Bosch Research.
- Tabellion: secure legal contracts on mobile devices. MobiSys'20 [Paper] [Code]
- Ongoing A physically isolated TEE design with high performance and utilization.